Autonomous VTOL UAV
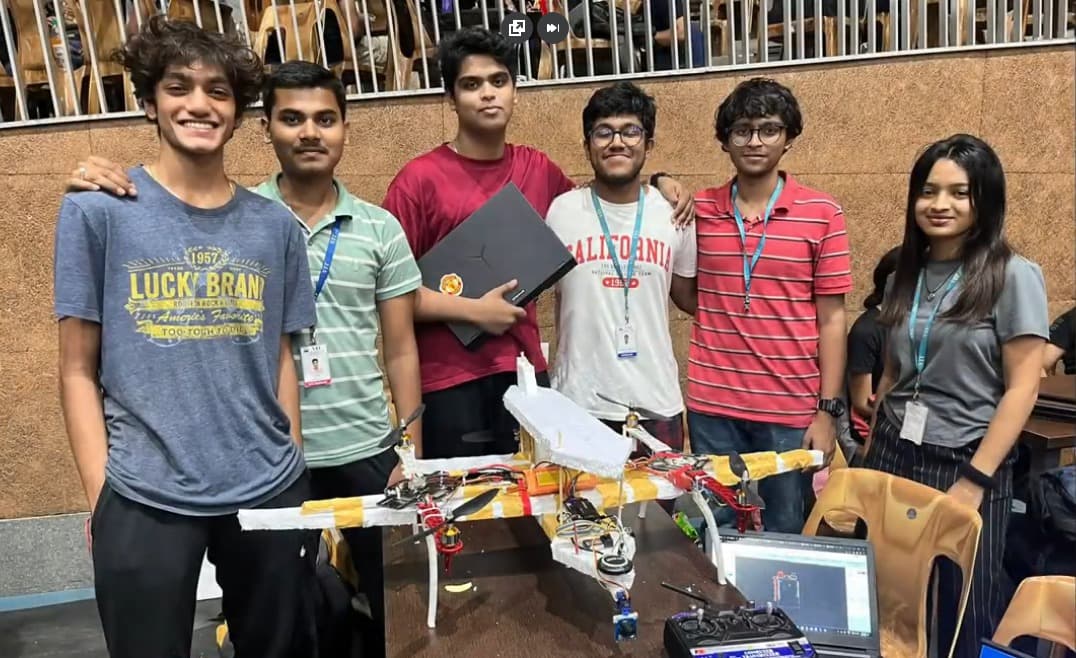
A search-and-rescue airframe with thermal victim detection
A vertical-takeoff platform built to search an area no one can walk into, and to find a person by heat rather than by sight.
Problem
Searching a disaster site from the ground is slow and sometimes impossible. Searching it from the air is fast and nearly useless if the only sensor is a colour camera pointed at rubble that looks like more rubble.
Vertical takeoff matters for the same reason: there is rarely a runway where the search is.
What I built
An airframe that can take off anywhere and detect on board.
- Raspberry Pi and Pixhawk airframe flown through MAVROS
- Autonomous scan patterns over the search area
- OpenCV and thermal imaging for victim detection
- Dataset preparation, with TensorFlow Lite and YOLOv5 inference on board
- Custom battery management for the endurance a scan pattern needs
A search pass
Detection runs on the aircraft rather than on a ground station, because the link is the first thing to go at a disaster site.
Vertical takeoff
No runway needed, which is the point of the airframe.
Fly the scan pattern
Autonomous coverage of the search area via MAVROS.
Detect on board
Thermal and visual, TFLite and YOLOv5 on the Raspberry Pi.
Heat signature with visual support, flag the positionNothing, continue the patternReport to the rescue team
Limitations and failure modes
- A prototype. It was flown and it detected, but it was never deployed in a real rescue and has no repository behind it.
- Thermal detection finds warm bodies, which in a real site includes fires, machinery and animals. Discrimination was not solved.
Gallery
Attribution
- Built by me
- The airframe integration, flight software, scan patterns, detection pipeline and battery management.
- Based on external research
- Pixhawk, MAVROS, YOLOv5 and TensorFlow Lite are upstream.
Related
- Pushpak Viman
Finding people under debris, from a transforming drone